Systems for Perception, Action, Reasoning, and Knowledge
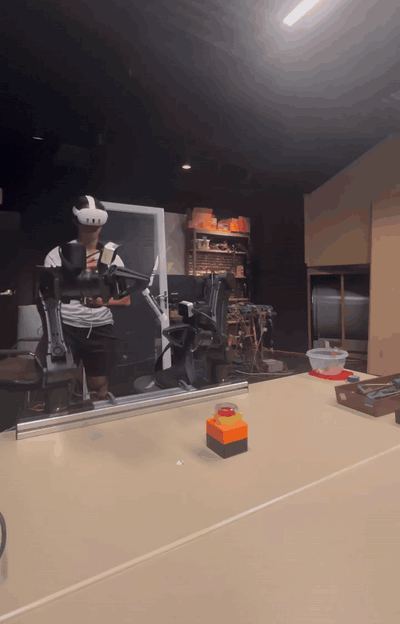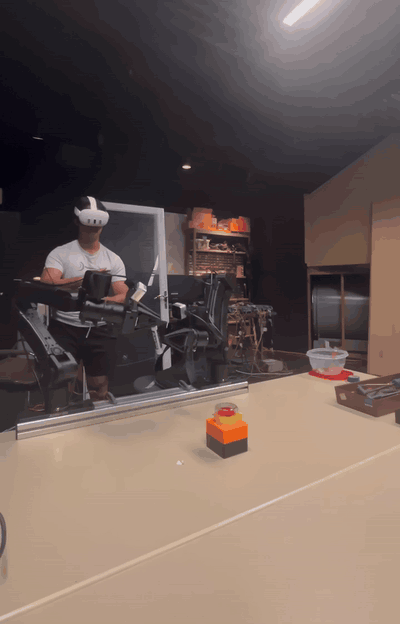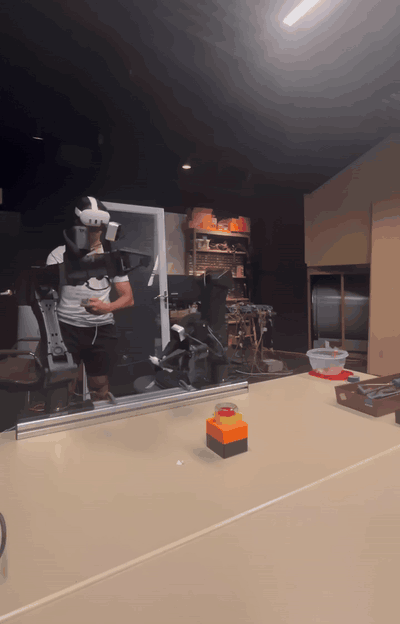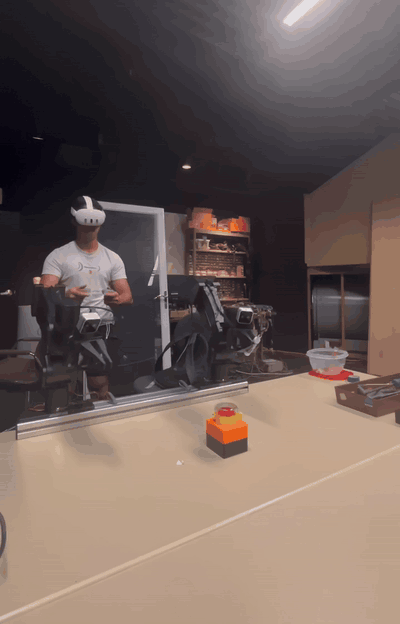
We study the convergence of automation and intelligence. Our mission is to build Lifelong Embodied Agents: intelligent systems that perceive, act, remember, and improve forever, by learning from real interaction.
Our research Join usSPARK Lab is part of the NSF Center for Human and Robot Co-Adaptation
A $30M, five-year NSF center led by UT Austin with Indiana University, MIT, Tufts, Yale, and the University of Utah, studying how people and robots learn from each other over long-term, real-world interaction. Read the announcement.
Research
Our work toward Lifelong Embodied Agents spans three threads: computer use, embodied multimodal agents, and NLP. Pick a thread to browse related papers.

TimeWarp: Evaluating Web Agents by Revisiting the Past
A benchmark for how robust web agents are to website UIs changing over time.
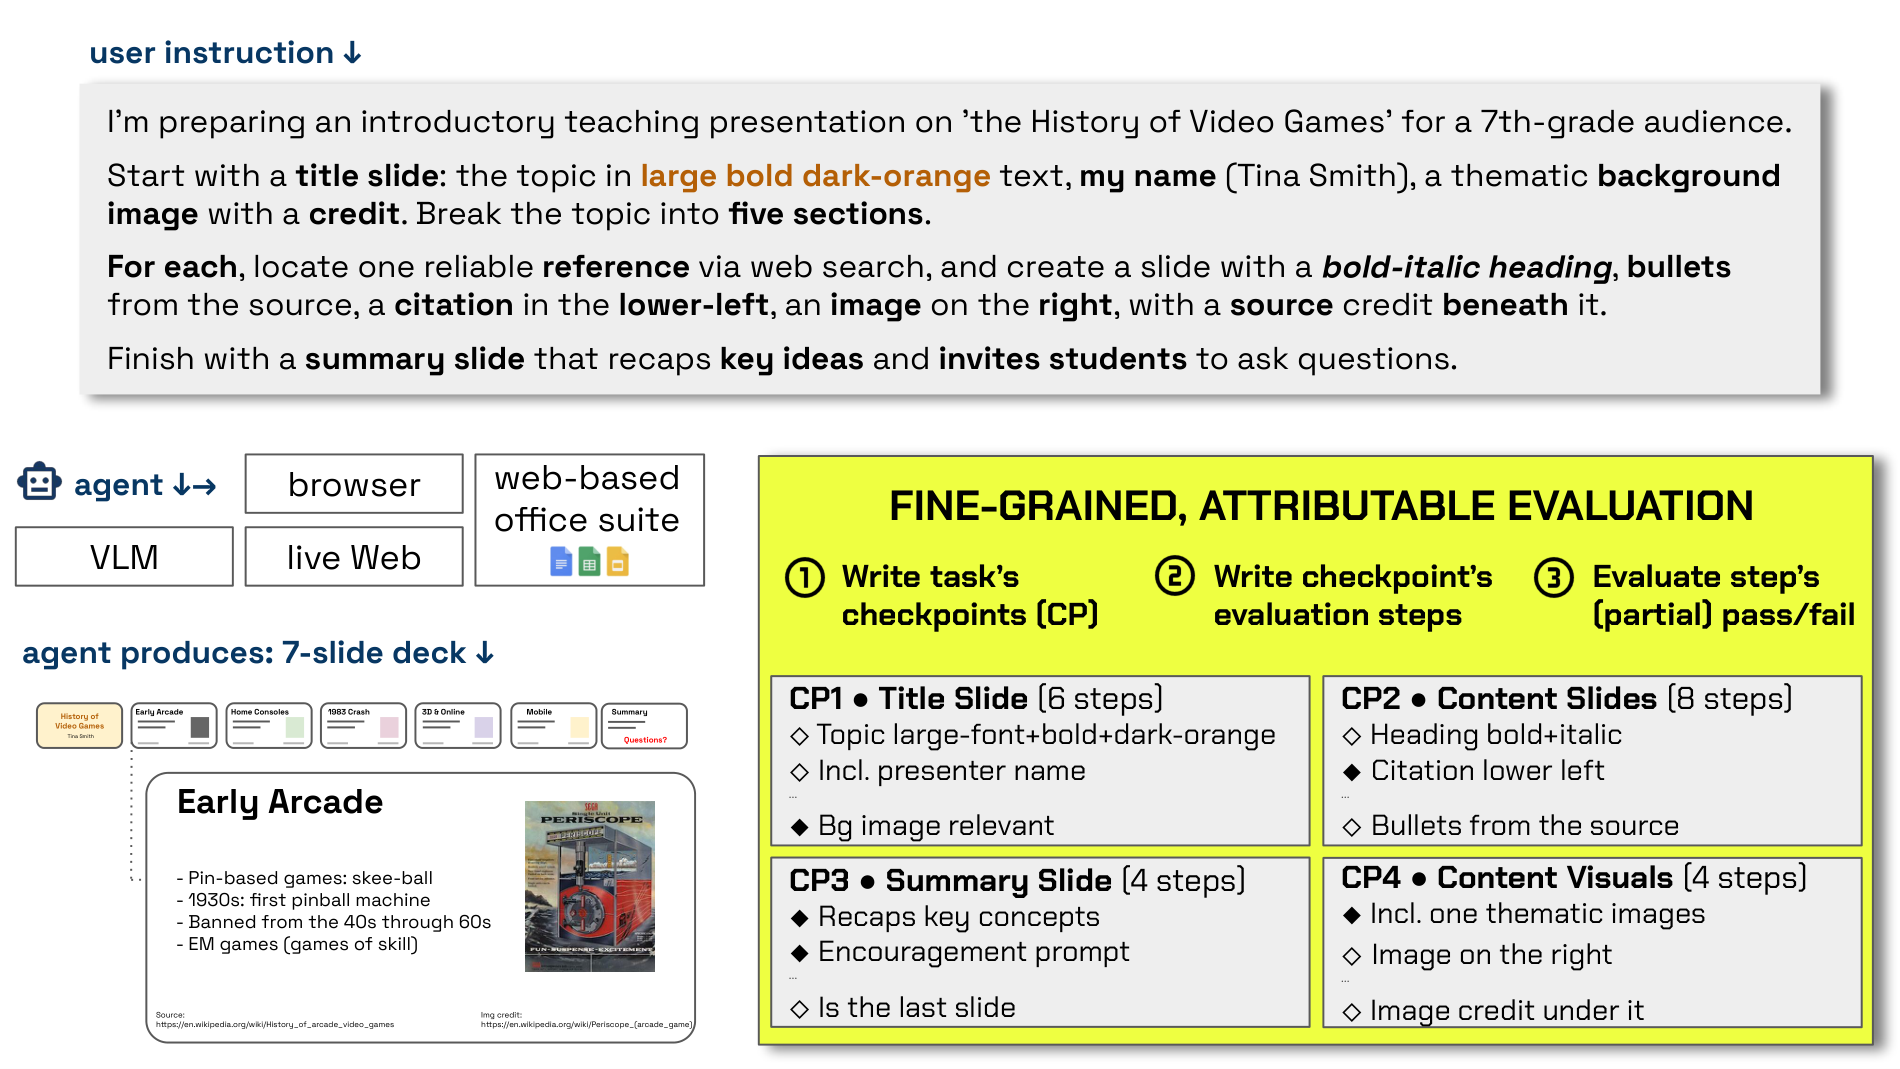
The Hard Part Comes After Search: Benchmarking Web Agents on Synthesizing, Organizing, and Displaying Knowledge
KNOWS tests whether web agents can turn what they find into usable artifacts, not just retrieve it.
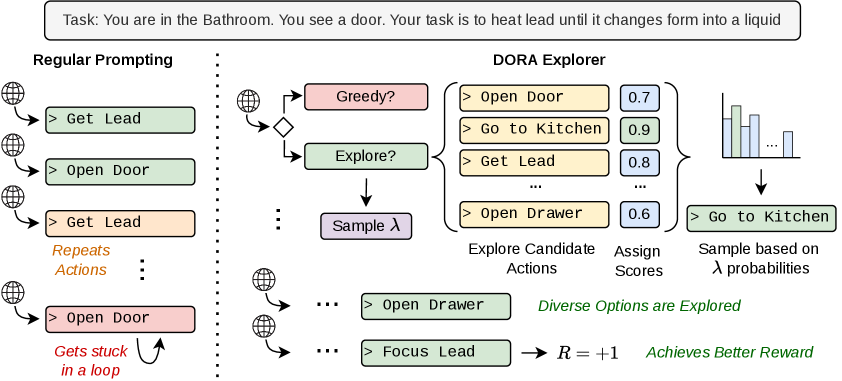
DORA Explorer: Improving the Exploration Ability of LLMs Without Training
Training-free exploration for LLM agents.

Computer Use Survey: A Visual Survey of Computer Use Agents
An illustrated tour of how computer-use agents work today.

BriefMe: A Legal NLP Benchmark for Assisting with Legal Briefs
A benchmark for language models that help write legal briefs.

Language Agents Mirror Human Causal Reasoning Biases. How Can We Help Them Think Like Scientists?
Language agents share human biases when exploring causal structure, and we show how to correct for them.

Efficient Exploration and Discriminative World Model Learning with an Object-Centric Abstraction
An object-centric abstraction that makes exploration efficient and world models easier to learn.

VLM Agents Generate Their Own Memories: Distilling Experience into Embodied Programs of Thought
Agents turn their own experience into reusable memories and get better over time.
News
- September 2026 TimeWarp has been accepted to NeurIPS 2026!
- September 2026 SPARK Lab joins the new $30M NSF Center for Human and Robot Co-Adaptation, alongside UT Austin, Indiana University, MIT, Tufts, and Yale.
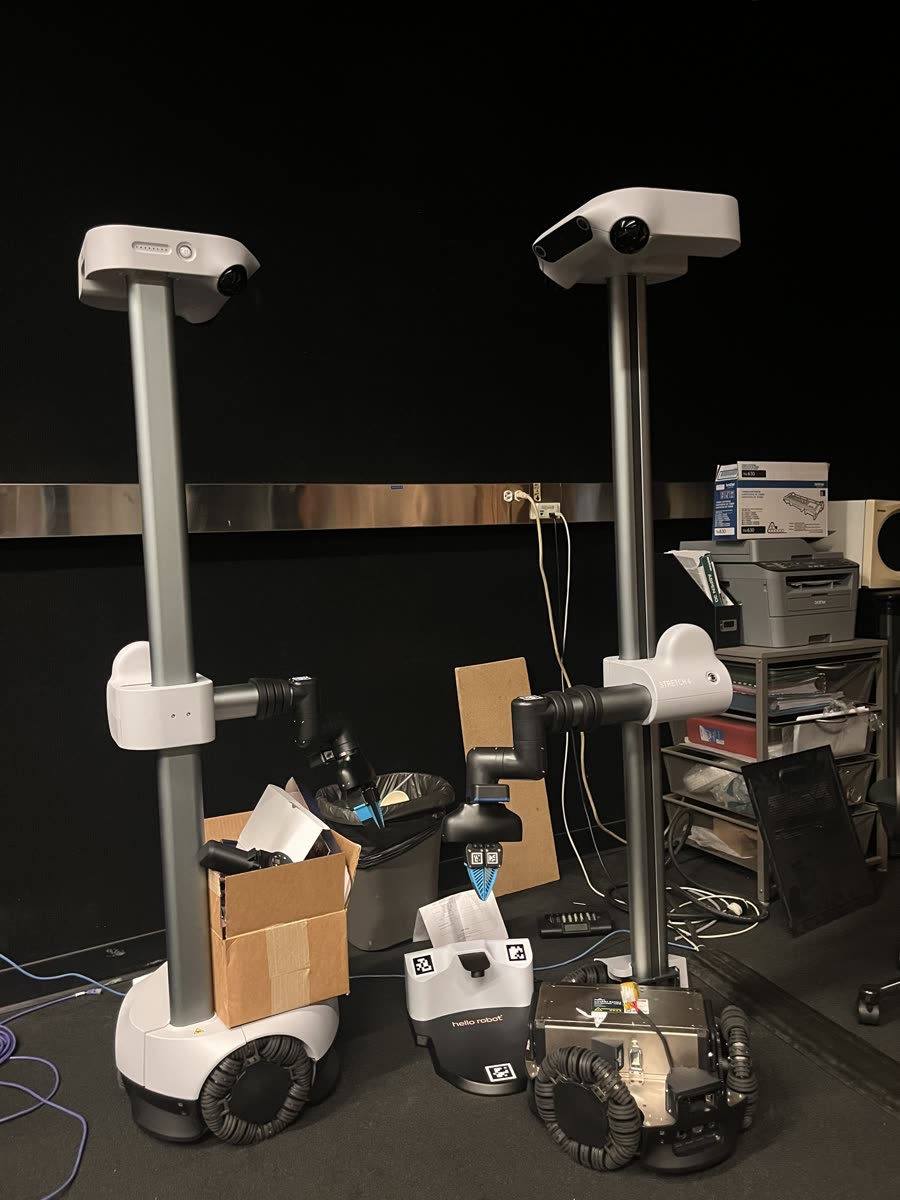
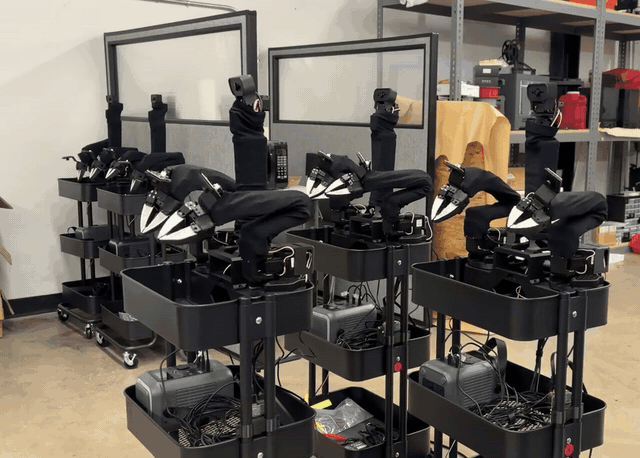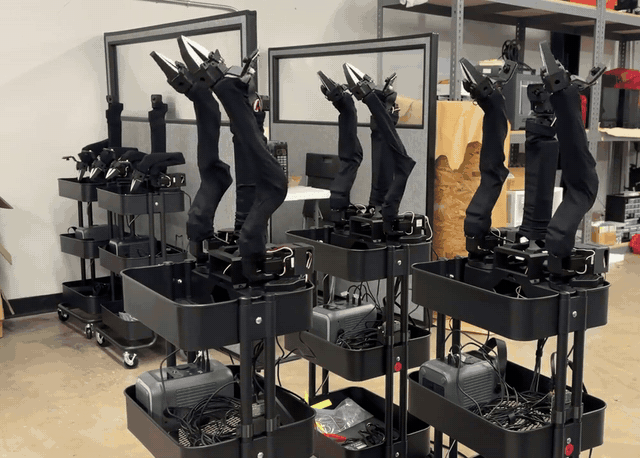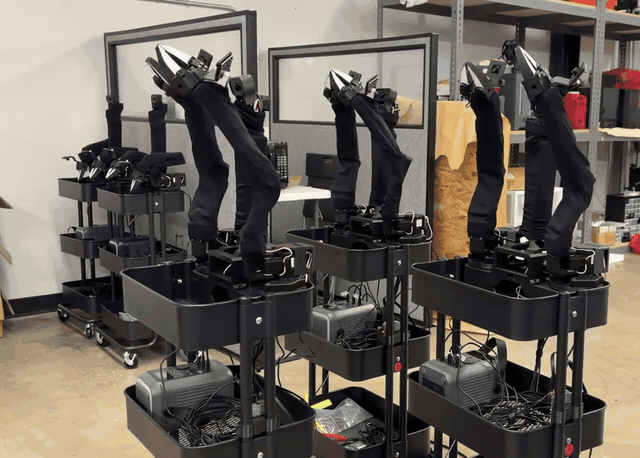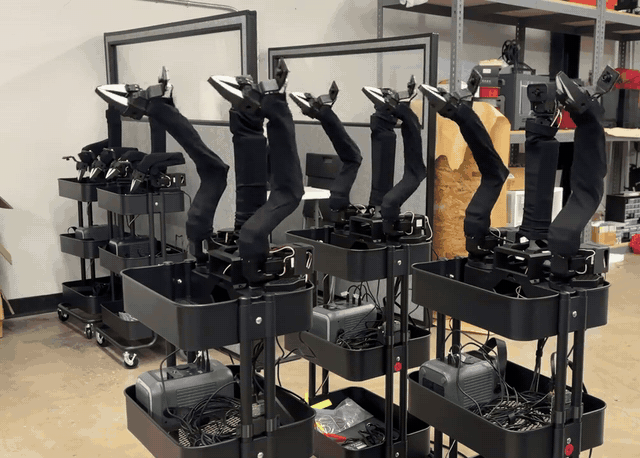
- September 2026 New robots have arrived in the lab!
- August 2026 Our web agent benchmark KNOWS, a collaboration with Utah NLP, has been accepted to Findings of EMNLP 2026!
- August 2026 New member, Minh Pham-Dinh, joined SPARK Lab!
- July 2026 Check out our new work on training-free exploration for LLM agents, DORA Explorer.
- March 2026 We launched the website for SPARK Lab!
- March 2026 Check out our web agent benchmark, TimeWarp.
- February 2026 Our Computer Use Survey has been accepted to ICLR Blogposts 2026!
- January 2026 Two new members, Dai-Jie Wu and Priya Gurjar, joined SPARK Lab!
Life at SPARK